
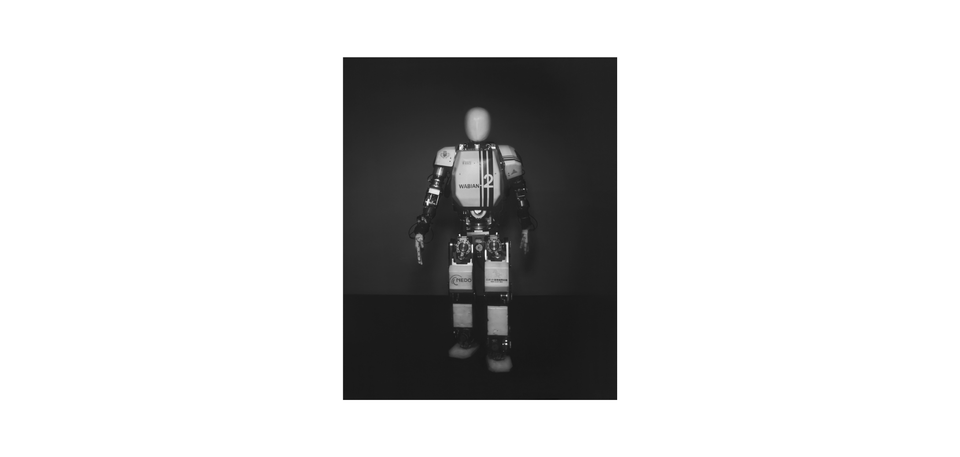
Robot Wabian
WABIAN-R, Humanoid Robotics Institute of Waseda University, Japan
WABIAN-R is a bipedal, autonomous humanoid robot developed by the Humanoid Robotics Institute at Waseda University in Japan. The robot is designed to mimic human walking dynamics and is often used as a motion simulator for testing equipment and physical rehabilitation exercises. The WABIAN robots are uniquely designed to extend their knees and walk using a reverse pendulum motion – the same biomechanical method that humans use to walk – enabling them to move forwards, backwards and sideways. The project, led in particular by Professor Atsuo Takanishi, provides essential kinematic data to engineers working on medical and rehabilitation equipment.